Aircraft overhead: ADS-B on 1090 MHz
Airliners and most other aircraft broadcast who and where they are, twice a
second, on 1090 MHz. This is ADS-B (Automatic Dependent Surveillance –
Broadcast). ./devkit adsb receives those messages with the board, decodes
them on your PC and shows them live: one row per aircraft, with its callsign,
altitude, speed and position, above a log of every message received.
This page covers what the window shows, the settings, recording and how the decoder works. To get a table of aircraft on screen, see track aircraft.
- antenna: a 1090 MHz antenna on RX1A (or RX2A with
--channel 2), with a view of the sky - power: a mains charger: on laptop bus power the board hangs under a sustained 4 MSPS stream
- gain: 25 dB manual by default; more is not better without a filter in front
- rate: 4 MSPS, 16 MB/s on the cable
- transmits: never: it only receives, so there is no transmit gate to pass and no licence question
Quick start
The three steps (antenna, mains power, ./devkit adsb):
track aircraft. Aircraft are line of sight: walls
and hills cost more range than anything else. Power matters because on bus
power the board hangs under a sustained 4 MSPS stream, which is all this tool
does.
The first run fetches PyQt6, the window toolkit, into uv's cache (about
100 MB, once). Without uv: a venv with .venv/bin/pip install PyQt6 numpy,
or the terminal version, which needs only numpy:
# run from: the repo root
./devkit adsb --text                     # messages, plus a table every 10 s
./devkit adsb --text --json --seconds 60 # one minute, then the table as JSON
What you see
The table has one row per aircraft heard in the last minute; rows turn grey after 30 s of silence. Click a column header to sort, and tick Log: selected aircraft only to follow one aircraft.
| column | meaning |
|---|---|
| ICAO | the aircraft's permanent 24-bit address, in hex. Unique worldwide |
| Callsign | the flight number (e.g. KLM1023), when the aircraft sends one |
| Squawk | the four-digit code air traffic control assigned. Comes in replies to radar, not ADS-B, so not every aircraft shows one |
| Altitude ft | barometric altitude |
| Speed kt, Track ° | ground speed and direction over the ground. Marked TAS/IAS when the aircraft reports airspeed and heading instead |
| V/S fpm | climb (+) or descent (−), in feet per minute |
| Latitude, Longitude | once two position messages have been paired (below) |
| Msgs | messages received from it |
| Signal dBFS | how strong it arrives: 0 is the receiver's full scale, so −10 is strong and −40 is weak |
The log shows every message whose checksum holds:
00:38:46.367 -16.6 dBFS CRC ok 40621D 8D40621D58C382D690C8AC2863A7 ADS-B position 38000 ft even 52.2572,3.9194
In order: time, signal level, how far to trust it (below), the aircraft's address, the raw message in hex, and what it says.
How far each message is trusted
Every message ends in a 24-bit checksum (a CRC). How to read it depends on the kind of message, and treating them all the same is how decoders fill up with aircraft that don't exist:
| mark | meaning |
|---|---|
CRC ok |
ADS-B (downlink format 17/18) or an all-call reply (DF11): the checksum proves the message intact |
fixed1 |
ADS-B with exactly one bad bit, which the checksum located and repaired |
AP ok |
a reply to a ground radar (DF0/4/5/16/20/21). Its checksum is mixed with the aircraft's address, so it proves nothing by itself; it is shown only when that address was already heard in a CRC ok message in the last minute |
Everything else is dropped and only counted, as rejected in the status bar.
Some rejects are normal
Noise sometimes looks like the start of a message.
Positions
To save bits, a position message carries only part of the latitude and longitude. Aircraft alternate between two encodings, called even and odd (the scheme is CPR, Compact Position Reporting).
| first position | one even and one odd message, received within 10 s of each other, give the position anywhere on Earth: it appears a second or two after the first position message |
| after that | each new message decodes alone, relative to the last position |
with --lat/--lon |
every position message decodes on its own, from the first (valid for aircraft within about 300 km) |
Give your own location and every position message decodes on its own, from the first one (valid for aircraft within about 300 km):
# run from: the repo root
./devkit adsb --lat 50.85 --lon 4.35
Settings
| option | what it does | default |
|---|---|---|
--channel 1\|2 |
which receiver the antenna is on: RX1A or RX2A | 1 |
--gain DB or agc |
receive gain; live in the window | 25 dB, manual |
--min-snr DB |
how far a message's opening pulses must stand above the noise floor | 9 dB |
--uri ip:HOST |
the board, when it is not found by itself | found by tools/board_addr.py |
--record NAME |
also save the raw samples, as SigMF | off |
--replay FILE |
decode a recording instead of the board; --fast, --loop |
— |
Gain. Manual is the default because ADS-B arrives in 120 µs bursts with silence between, and the AD9361's automatic gain hunts between them.
More gain is not better here
Nothing in front of the AD9361 filters out other bands, so a strong signal elsewhere (mobile networks near 900 and 1800 MHz) reaches the receiver along with the aircraft. On one outdoor test with a 1090 MHz antenna on RX2A, the noise floor rose about 8× between 30 and 40 dB of gain, where 3× would be normal: the receiver was overloading. Aircraft decoded at 20–25 dB and at no higher gain.
| Gain | When |
|---|---|
| start at the default 25 dB | always |
| step down | if the rejected count climbs while nothing passes the checksum |
| step up | only while the noise floor rises by no more than the gain does |
For real range, add a 1090 MHz filter and amplifier in front of the board
A filtered ADS-B amplifier, sold for exactly this. The filter removes the strong out-of-band signal, so the gain can go up without burying the aircraft.
The sample rate is 4 MSPS (million samples per second). Each half-bit of a message then lasts exactly two samples, so the demodulator never has to guess. That is 16 MB/s over the cable, within the 5 MS/s the USB link carries.
Recording and replaying
# run from: the repo root
./devkit adsb --record flight                   # flight.sigmf-data + .sigmf-meta
./devkit adsb --replay flight.sigmf-meta        # no board needed
./devkit adsb --replay flight.sigmf-meta --text --fast
- At 4 MSPS a recording grows by 16 MB per second, about 1 GB a minute.
- If the disk fills, the recording stops, the status bar says
RECORDING STOPPED, and reception carries on.
A replay tells \"the antenna hears nothing\" from \"the decoder misses it\"
If a recording of a busy minute decodes nothing, the problem is in the samples.
When the table stays empty
| Symptom | Cause | Fix |
|---|---|---|
status bar: LINK TOO SLOW |
fewer samples arrive than the receiver produces, and whole messages are lost. On one bench, fishball.local resolved to an IPv6 link-local address that delivered 1.3–2.5 MS/s, while the USB address delivered the full 4 |
--uri ip:192.168.2.1, or export BOARD=192.168.2.1 |
status bar: NO SAMPLES for N s |
the board stopped delivering. Usually power: on a laptop's USB port the board hangs under this load | power it from a mains charger, then check ./devkit status |
rejected keeps rising but nothing is CRC ok |
the receiver hears something shaped like a message, but nothing intact. Usually noise | check the antenna and its cable first, then try a few dB less or more gain |
| nothing at all, and the signal never moves | the antenna is not on the port --channel names |
check it; then ./devkit adsb --record test for 10 s and look at the recording in any SigMF viewer: aircraft show as short spikes well above the noise |
| "something else holds the receiver" | SDR++, a capture, or the hardware CI has the receive buffer | close it; only one program can stream at a time |
| few aircraft late at night | there are far fewer aircraft | daytime near any airway usually gives several within a minute, with an outdoor antenna |
How the decoder works
The code is in tools/adsb/, in plain Python and numpy:
| file | does |
|---|---|
source.py |
sets up the receiver with iio_attr, reads every setting back, and streams with iio_readdev; or reads a recording |
demod.py |
finds messages in the samples |
modes.py |
checksums, fields, positions, and the aircraft table |
engine.py |
runs the two in threads, so a slow screen never stalls the stream |
gui.py, adsb.py |
the window, and the command line |
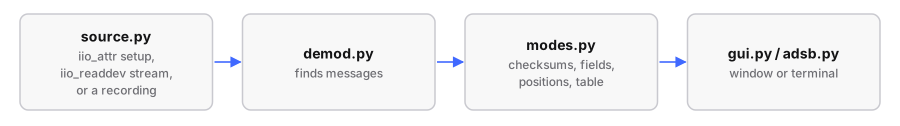
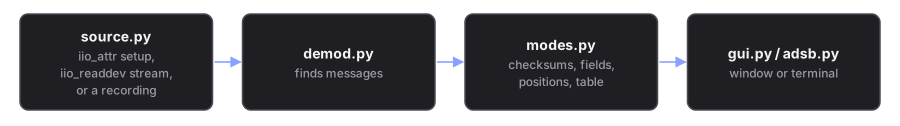
The receiver is tuned to 1090 MHz exactly, so a message arrives as a pattern of on/off pulses, and only each sample's magnitude matters. Each message starts with four pulses in a fixed pattern (the preamble), then the bits: each bit is 1 µs, with the pulse in the first half for a 1 and the second half for a 0. This is called pulse-position modulation. The demodulator scores every sample as a possible preamble start, at once with numpy. Wherever the four pulses stand out from the gaps between them, it reads 56 or 112 bits, depending on the message type in the first five. Blocks of samples overlap by one whole message, so a message split across two blocks is found once.
tools/adsb/test_adsb.py checks all of it with no board and no antenna.
Field values come from an independent decoder (pyModeS), compared across every
altitude and squawk code. The demodulator is checked end to end on synthetic
messages with random carrier phase, a 50 kHz frequency offset, noise, and
arbitrary block cuts.
# run from: the repo root, with numpy in a venv (python3 -m venv .venv; .venv/bin/pip install numpy)
.venv/bin/python tools/adsb/test_adsb.py